Office
Open a jar
EngramEgo
Generative 4D
hand–object reconstruction
From first-person recordings, we reconstruct how hands and objects move together in 3D over time. Explore a grasp, follow the object’s motion, and compare the reconstruction with the recorded action.
Generative 4D reconstruction
Reconstruct hand–object interaction over time
Reconstruct hand geometry, object motion and their spatial relationship from first-person recordings. Compare the footage with the 3D result to follow how the interaction changes over time.
Look closer at the hand geometry
In these HOT3D examples, the estimated hand mesh follows the fingers as they grip a utensil or lift a bowl. The views below show the grasp in finer detail.
10.61 mmWrist-aligned joint error (MPJPE-p)
2.09×Speedup over our previous version
EngramEgo data samples
Explore a recorded episode
This bowl-and-lid recording is one of our data samples. Open EngramEgo to inspect the camera views, depth, head pose and inertial readings on the same timeline.
Browse the data samples on EngramEgoTask coverage
People at work, at home and on the move
These 21 first-person clips show the tasks being recorded, from tightening a screw at a workbench to choosing groceries in a shop.
Office
Close a laptop
Office
Fill a cup at the dispenser
Office
Wash and dry hands
Convenience store
Choose snacks from a shelf
Convenience store
Inspect a packet of chilled noodles
Convenience store
Pick out vegetables
Convenience store
Turn a bottle to read the label
Convenience store
Scan a bottle at the self-checkout
Restaurant
Pick up noodles with a fork
Travel
Use the steering-wheel controls
Travel
Open a parcel locker
Travel
Unscrew a bottle cap on the metro
Clothing store
Check a garment tag
Factory
Tighten a screw on a bracket
Factory
Sort tools and parts
Home
Take a drink from the fridge
Home
Wash hands at home
Mall
Read an information leaflet
Mall
Try a keyboard and a phone
Mall
Connect a phone to a shared power bank
Hardware
Capture hardware
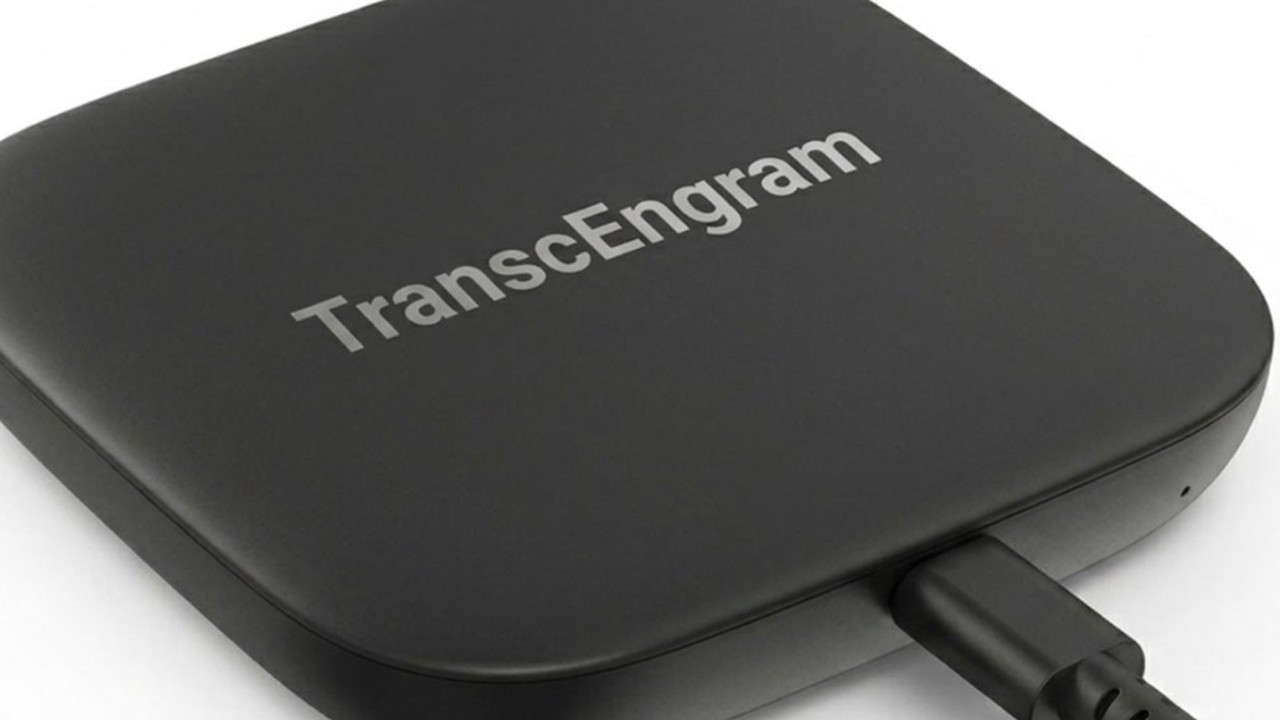
The headband carries four cameras and an inertial sensor. A portable processing unit synchronizes the signals and displays depth and hand keypoints during recording.
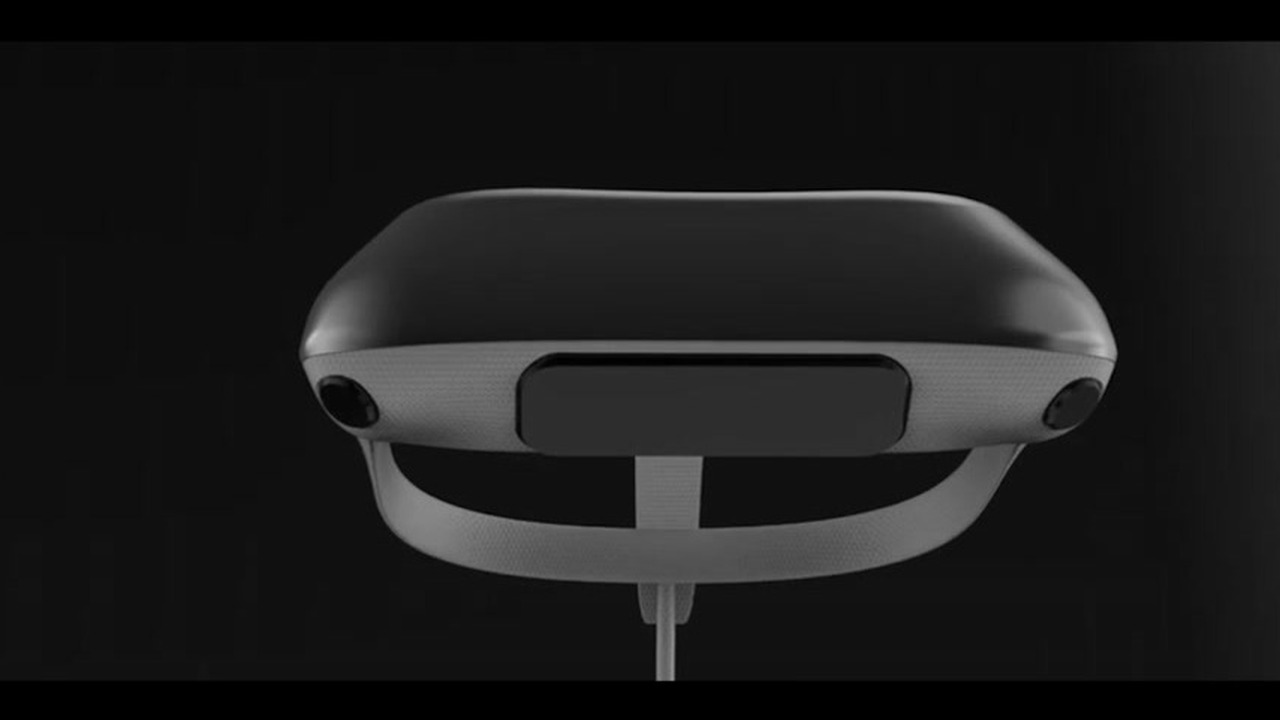
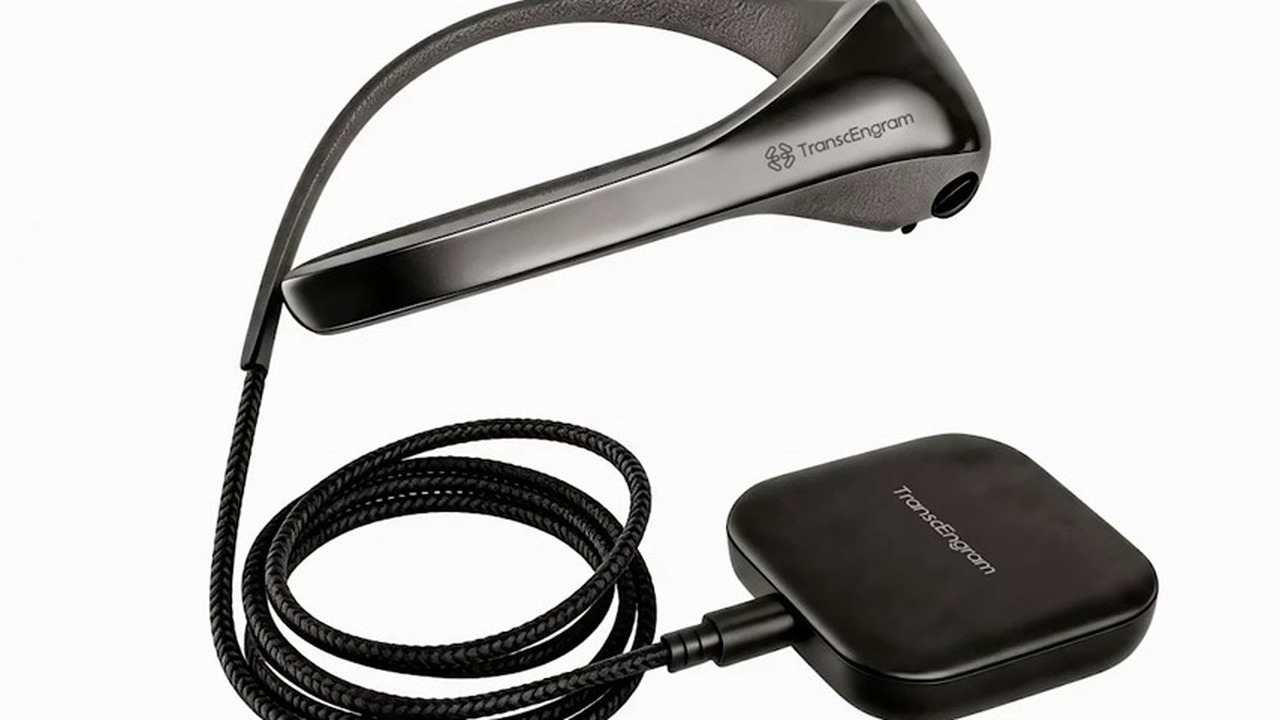
Capture and recording controls
| Cameras | Two wide-angle cameras and two fisheye cameras |
|---|---|
| Depth | Depth is estimated on the device in real time and synchronized with the RGB video. |
| Muscle activity | Multichannel EMG from a forearm band |
| Voice controls | Voice commands start or stop recording. An audio prompt alerts the wearer when a hand moves out of view. |
| Motion | 6DoF head pose, plus accelerometer and gyroscope readings at 400 Hz |
| Sample playback | Seven synchronized streams in the sample, with camera video at about 30 fps |
Device specifications
| Headband | 350 g · 8 h of continuous capture |
|---|---|
| Camera array | 4 global-shutter cameras · 300° × 137° combined field of view |
| Stereo pair | 1920 × 1200 per camera · 110° × 80° field of view |
| Fisheye cameras | 1920 × 1200 per camera · 204° × 137° field of view |
| On-device processing | 34 TOPS of AI compute |
| Outputs | Multiview video, with 3D body, hand and object motion available after reconstruction |